Browse categories
Explore
Fiverr Pro
English
$
USD
Robotics and Automation Engineer
Are you looking for a ROS2 developer to build, simulate or configure an autonomous mobile robot?
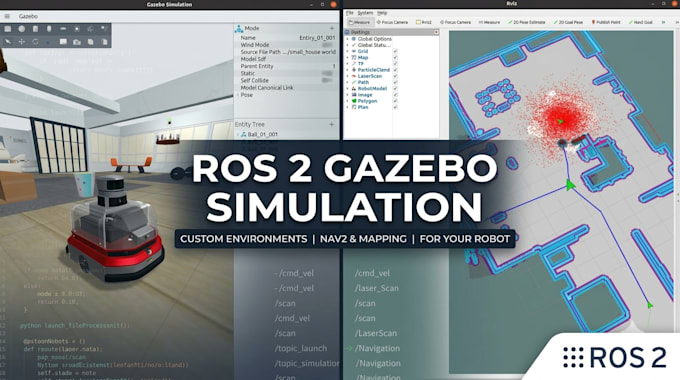
I provide ROS2-based robotics development and simulation services for autonomous mobile robots (AMRs), warehouse robots, research prototypes and robotics applications.
What I can develop:
ROS2 robot simulation using Gazebo
URDF/Xacro robot model configuration
LiDAR and camera sensor integration
SLAM and 2D map generation
AMCL localization
Nav2 autonomous navigation
Path planning and obstacle avoidance
Waypoint-based navigation
Custom Gazebo environments
Python/C++ ROS2 nodes
Launch files and project documentation
Technologies:
ROS2 | Gazebo | Nav2 | SLAM Toolbox | RViz2 | Python | C++ | URDF | OpenCV
What you will receive:
Organized ROS2 project workspace
Source code and configuration files
Simulation and navigation setup
Installation and execution instructions
Demo video or screenshots
Support for resolving agreed project-related issues
Whether you are developing a warehouse AMR, testing a robotics concept, or building a research prototype, I can help turn your requirements into a working simulation.
Please contact me before ordering so we can discuss your robot model