I will ros 2 and gazebo simulation engineering

E
echo_rz
E
echo_rz
Echo Zhang

About this gig

Having trouble with your ROS 2 or Gazebo simulation? I can help you identify issues, fix configuration problems, and get your robotics project running.

My services include:

  • ROS 2 package and colcon build troubleshooting
  • Node, topic, launch file and parameter debugging
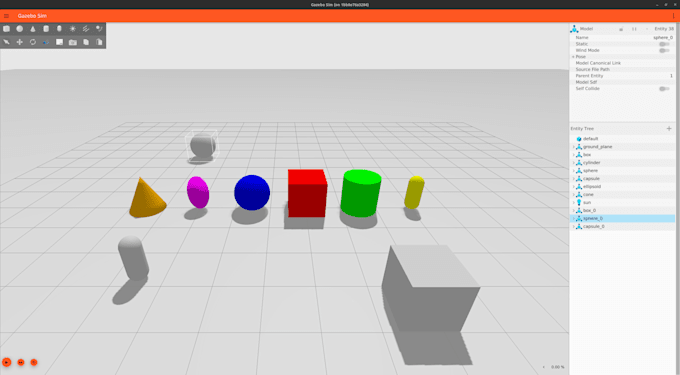
  • Gazebo simulation setup and troubleshooting
  • URDF/SDF model loading and configuration issues
  • Sensor plugin and ROS topic integration
  • Python scripts for simulation and automated data collection
  • Testing and debugging existing robotics simulation projects

Tools and technologies:

ROS 2, Gazebo Sim, Python, Linux, Docker.

What you will receive:

  • Updated source code and configuration files
  • Reproducible launch and run instructions
  • A summary of identified issues and implemented fixes
  • Simulation validation results when the supplied environment allows reproduction

I primarily work with existing projects and clearly scoped tasks. Full custom robot development, complex navigation systems, hardware firmware, and large-scale simulation environments require a separate assessment.

Please contact me before ordering complex projects. I communicate primarily through Fiverr messages and prefer clear, documented technical requirements.

Get to know Echo Zhang

Echo Zhang

Python Developer , Robotics Researcher

  • FromChina
  • Member sinceSep 2026
  • Languages

    English
I'm a Python developer and robotics researcher specializing in robotics, computer vision, and scientific computing. I've co-authored research papers for IEEE T-ASE and OCEANS, with additional research submitted to ICRA . I have hands-on experience with Python, ROS 2, Gazebo, and Docker, particularly in robotics simulation and automated data collection. I can help with: Python data processing and analysis Scientific plots and data visualization Robotics simulation and troubleshooting with ROS 2 and Gazebo I provide clearly scoped deliverables and communicate primarily through messages.