Browse categories
English
$
USD
Connect to your AI
PCB Design, Embedded System, IOT and Firmware Development
Struggling to connect your robot's motors, sensors, and controller into one reliable system?
I will design custom robotics PCBs and embedded hardware using ESP32, motor drivers, ROS2 compatible interfaces, LiDAR and IMU sensors to help bring your robotics project to life.
What I can do for you:
Whether you're building an autonomous mobile robot, a research prototype or a robotics MVP, I'll help you develop a practical hardware solution tailored to your requirements.
Why work with me?
Packages start at $100. Final pricing depends on PCB complexity, motor specifications, sensor requirements, firmware and ROS2 integration.
Message me before ordering to discuss your project and choose the right package.
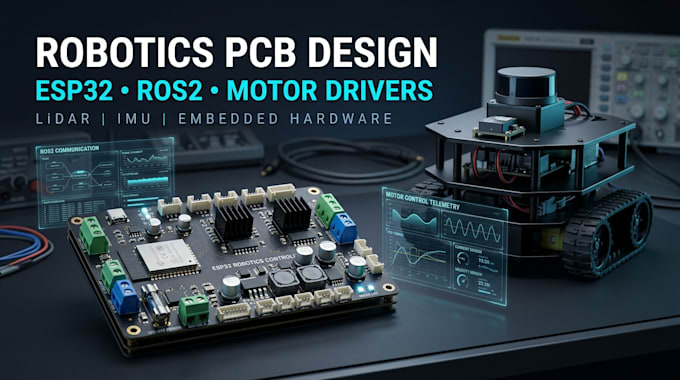
Can you design a custom PCB for a robotics project?
Yes. I can help design a custom robotics PCB, including schematics, component selection, PCB layout, motor interfaces, sensor connections, and manufacturing documentation according to the agreed scope.
Do you support ESP32 and STM32 controllers?
Yes. The hardware architecture can be designed around ESP32, STM32, or another suitable controller based on your robot's processing, connectivity, and peripheral requirements.
Can you integrate motor drivers into the PCB?
Yes. Motor driver circuitry and interfaces can be designed for supported DC, BLDC, or stepper motors. Please provide the motor voltage, current, control method, and encoder requirements.
Can you integrate LiDAR and IMU sensors?
Yes. I can design suitable hardware interfaces for LiDAR, IMU, wheel encoders, and other supported sensors, subject to their electrical and communication requirements.
Can you make the hardware compatible with ROS2?
Yes. I can plan and implement suitable communication interfaces between the robot hardware and a ROS2-based system. The exact integration depends on the host computer, microcontroller, transport protocol, and required ROS2 nodes.
Will I receive manufacturing-ready PCB files?
Manufacturing documentation can include schematics, PCB source files, Gerber files, drill files, and a bill of materials, depending on the package. Physical fabrication and assembly are not included unless agreed separately.
Can you work on an existing robot or PCB design?
Yes. Existing designs can be reviewed, extended, or modified. Please share your schematic, PCB files, firmware, component datasheets, or ROS2 architecture so the work can be scoped accurately.
