Browse categories
English
$
USD
Connect to your AI
Prototyping, Reverse Engineering, Robotics and ERPNext
Level 1
Has met certain performance criteria and shows strong potential in the marketplace.
Stuck on a ROS 2 robot that won't build, localize or navigate? I'll help you get it working.
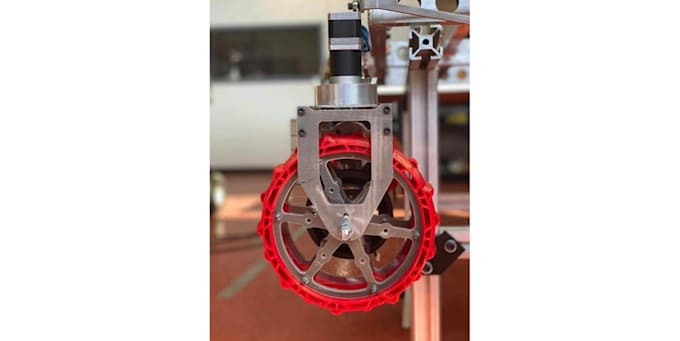
I'm a mechatronics engineer (McMaster University) and former VP Engineering of the McMaster Mars Rover team, which placed first in Canada at CIRC 2022. Our rover software ran on ROS, ROS 2 and Nav2. I've also built an autonomous delivery AGV for a manufacturing facility, and I currently work with Jetson-based robot arms.
I can help with:
You get working, commented code pushed to your repo, plus notes on what was changed and why.
Please message me before ordering with your ROS 2 version, robot hardware and what's going wrong, so I can confirm the right package.
Platform:
NVIDIA Jetson
Expertise:
Debugging
•
ROS
•
Robotics
Which ROS 2 versions do you work with?
Current LTS distributions on Ubuntu. Tell me your distro and hardware before ordering and I'll confirm it's a fit.
Do you need access to my robot?
Not always. Many issues can be fixed from your repo, logs and bag files. For hardware-specific tuning, a screen-share session or remote SSH access works best.
