Browse categories
Explore
Fiverr Pro
English
$
USD
ESP32 and FreeRTOS firmware engineer, LLM features in Python
I write ESP32 firmware in C on ESP-IDF and FreeRTOS: sensors read on time, task priorities chosen on purpose, and links that report stale data instead of acting on it.
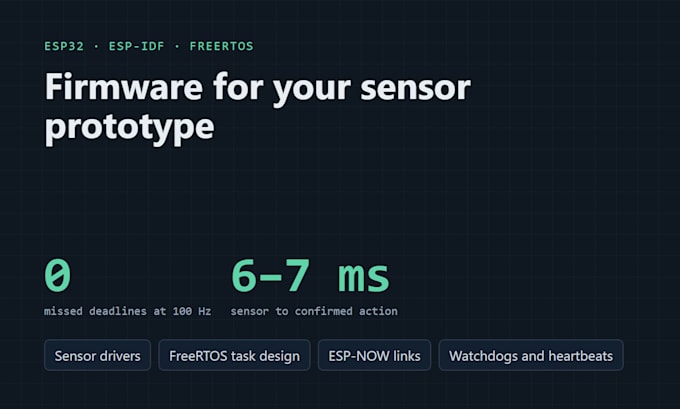
Shipped on my own bench: a two-board ADAS/ECU system over ESP-NOW. Ultrasonic distance read by GPIO interrupt, with filtering that removed two kinds of phantom braking; a 100 Hz control loop with 0 missed deadlines; framed radio messages with sequence numbers and re-pairing after a reboot; a supervisor that can tell a silent sender from a receiver that can't act; 6-7 ms from sensor to confirmed action.
What I can build for you: sensor drivers with filtering (GPIO, UART, I2C, SPI); FreeRTOS task design with priorities, core pinning, queues and ISR hand-off; ESP-NOW links between boards; watchdogs, heartbeats and fault reporting; and CMake/Kconfig builds with one firmware per board role.
What you get: source in a Git repo, build steps, a README of the design decisions, and logs from the board.
Tell me your sensors and radio, and I'll say plainly what I've done before and what will be new.

Platform:
ESP32
Expertise:
Firmware development
•
RTOS
•
Microcontrollers
Arduino or ESP-IDF?
ESP-IDF by default. It gives full control of FreeRTOS, and it's what I've shipped on. If you need Arduino, ask first.
Can you design the PCB?
No. I write firmware for dev boards and existing hardware; the PCB is a job for an electronics engineer.
