Browse categories
English
$
USD
Connect to your AI
Robotics Engineer for ROS2, Embedded Systems, PCB and Industrial Automation
Need a ROS2 robot that actually runs, not a half-working repo?
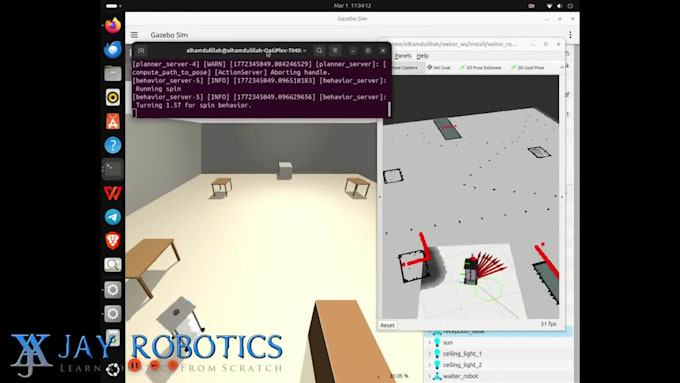
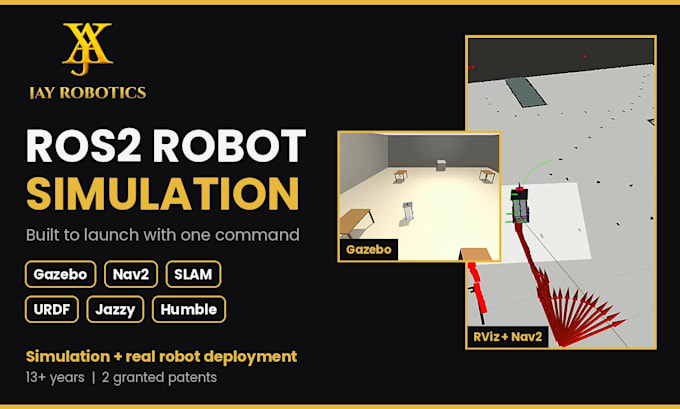
I am a robotics engineer with 13+ years of hands-on experience, 2 granted patents and international robotics competition podiums. My team and I build ROS2 simulations you can launch with one command.
What I can build:
- URDF/Xacro robot models (differential drive, 4WD, arms, custom)
- Gazebo simulation with lidar, camera and IMU
- Teleop and custom nodes in Python or C++
- SLAM mapping and Nav2 autonomous navigation
- Clean launch files and a README
Works on ROS2 Jazzy and Humble (Ubuntu 24.04 / 22.04).
You receive the full source workspace, launch instructions, and a demo video of it running.
Please message me before ordering so I can confirm scope and timeline.
Real hardware: I also work with ROS2 on real robots, not only in simulation. If you want your simulation moved to physical hardware, tell me your robot and sensors and I will quote it as a custom offer.
Platform:
NVIDIA Jetson
Expertise:
ROS
•
Programming
•
Robotics
Which ROS2 versions do you support?
ROS2 Jazzy (Ubuntu 24.04) and Humble (Ubuntu 22.04). Message me if you need another version.
Can you make it run on my real robot?
Yes. I work with ROS2 on real robots too. The packages here cover simulation; hardware deployment is quoted as a custom offer once I know your robot and sensors.
Will I get the source code and can I explain it in my project?
Yes. You get the full ROS2 workspace, launch instructions and documented code, so you can run it, modify it and explain how it works.