Browse categories
Explore
Fiverr Pro
English
$
USD
Are you facing bugs, errors, or integration issues in your ROS2 robotics project?
I can help you investigate, debug, fix, and improve ROS2-based robotics software using Python and C++.
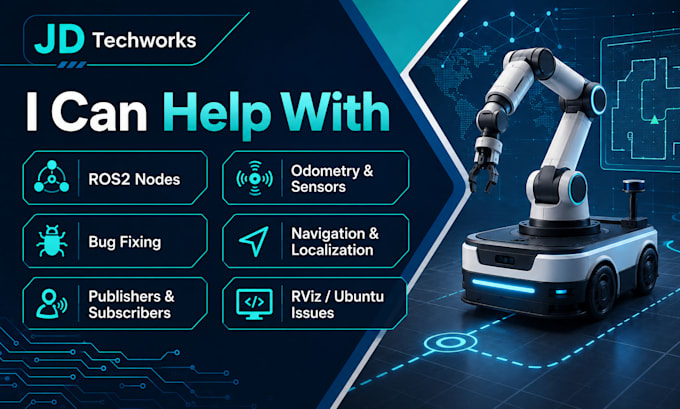
I can assist with:
ROS2 node debugging and development
Publishers, subscribers, topics, services, and launch files
Python and C++ ROS2 code
Odometry and sensor integration
Robot localization and navigation issues
Occupancy grids and motion-control debugging
Camera/computer-vision integration
ROS2 package, dependency, build, and Ubuntu environment issues
RViz troubleshooting, code testing, comments, and documentation
I have hands-on experience with mobile robotics, ROS2 communication, localization, odometry, autonomous navigation, computer vision, and simulation.
Please contact me before ordering for multi-node systems, hardware integration, or large codebases. Send your ROS2 version, Ubuntu version, code/package, error messages, expected behavior, and relevant logs or screenshots.
Freelance Robotics ROS2 Developer
Languages
What information do you need before starting?
Please provide your ROS2 distribution, operating system, relevant source code or package, error messages, expected behavior, current behavior, and any useful logs, screenshots, launch files, configuration files, or rosbag data.
Can you work with both Python and C++ ROS2 code?
Yes. I can work with Python and C++ based ROS2 projects. Please send the relevant files and project requirements so I can review the scope before starting.
Can you fix a complete ROS2 robotics project?
For small and medium issues, you can select one of the available packages. Large projects involving multiple nodes, navigation systems, sensors, simulation, or extensive integration should be discussed before ordering so I can provide a suitable custom offer.
Can you help with robot localization and navigation?
Yes. I have hands-on experience with mobile robot localization, odometry, occupancy grids, autonomous navigation concepts, motion planning, and ROS2-based mobile robotics systems.
Can you debug ROS2 installation or environment issues?
Yes. I can investigate ROS2 package, dependency, workspace, build, launch, and Linux/Ubuntu environment-related problems where they are within the agreed project scope.
Should I contact you before placing an order?
Yes, especially for Standard or Premium projects. Please send a short description of the problem first so I can confirm the scope, required files, package, and expected delivery time.