Browse categories
English
$
USD
Connect to your AI
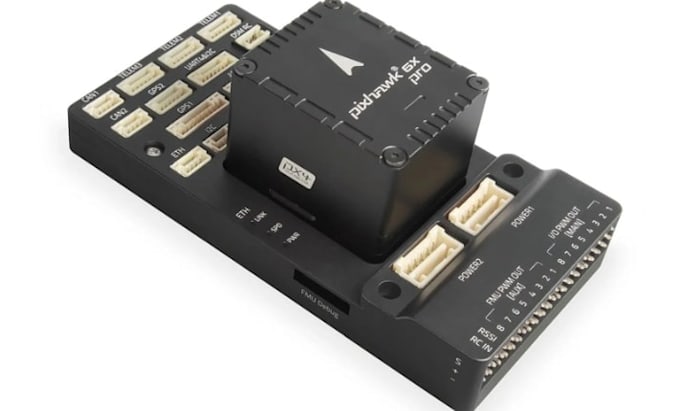
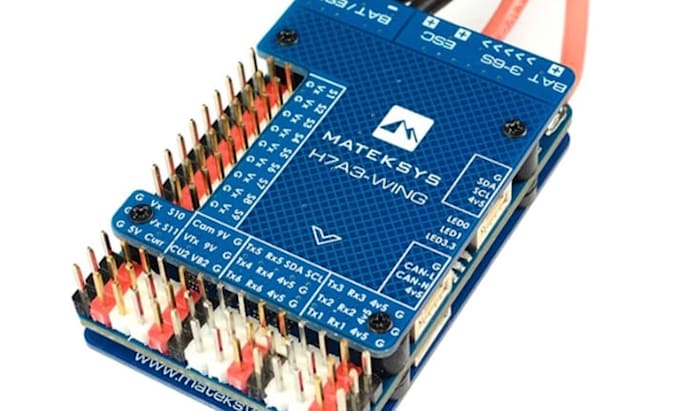
I design drone flight controller PCBs and Pixhawk-style autopilot hardware for multirotors, fixed-wing aircraft and autonomous UAVs. Each design starts with your I/O map, processor, sensors, power budget and mounting constraints.
Hardware options include STM32 F4/F7/H7, SPI IMU, barometer, magnetometer, GNSS, airspeed, OSD, blackbox flash, PWM/DShot outputs, UART, CAN, USB, SPI and I2C. I address details often missed in generic layouts: dedicated clean IMU power, separate sensor buses, noise-aware placement, vibration-conscious mounting, filtered rails, voltage/current monitoring, SWD debug access and labelled test points.
Deliverables include schematics, PCB layout, component selection, BOM and manufacturing files such as Gerbers and drill data. 3D fit checks and firmware-target planning can be scoped separately.
Designed around PX4, ArduPilot, Betaflight or INAV hardware requirements. Firmware porting, target approval, fabrication and flight testing are excluded unless agreed beforehand.
Send your airframe, firmware, board dimensions and required interfaces before ordering.
. Can you design a custom drone flight controller PCB for PX4 and ArduPilot?
Yes. I can develop STM32-based autopilot hardware around the selected PX4 or ArduPilot architecture, including sensor interfaces, PWM outputs, power management and communication peripherals.
Do you design Betaflight and INAV flight controller boards?
Yes. I can design FPV flight controller PCBs with compatible MCU resources, SPI gyroscopes, receiver interfaces, ESC connections, blackbox storage, OSD options and appropriate power regulation.
Which STM32 microcontrollers can you use for a flight controller?
I can work with STM32 F4, F7 and H7 families. Selection depends on processing requirements, motor outputs, available timers, DMA resources, communication interfaces and firmware compatibility.
Can you integrate IMU, GPS, barometer and magnetometer sensors?
Yes. I can integrate gyroscopes, accelerometers, GNSS receivers, barometers, magnetometers and airspeed interfaces with attention to sensor power, communication buses, placement and signal integrity.
Will you provide Gerber files and a complete PCB manufacturing package?
Yes. Depending on your package, deliverables include schematics, PCB source files, Gerbers, drill files, BOM and relevant assembly documentation.
Can you design a Pixhawk-compatible flight controller?
Yes. I can develop custom autopilot hardware following relevant Pixhawk reference standards, including connector definitions, power architecture, I/O mapping and peripheral interfaces.
. Can you reduce IMU noise and vibration-related problems in the PCB?
I consider dedicated sensor power regulation, decoupling, SPI routing, ground-plane design, component placement and mechanical mounting to reduce potential noise and vibration-related issues
Do you provide flight controller firmware and flight testing?
The primary service is custom PCB hardware design. Firmware development, bootloader integration, firmware target creation, prototype testing and flight validation can be discussed as separate project requirements.