Browse categories
Explore
Fiverr Pro
English
$
USD
PCB Design and CAD
I specialize in ROS2 navigation for holonomic and mecanum-wheel robots a niche most ROS developers avoid because standard differential-drive tuning simply doesn't transfer over.
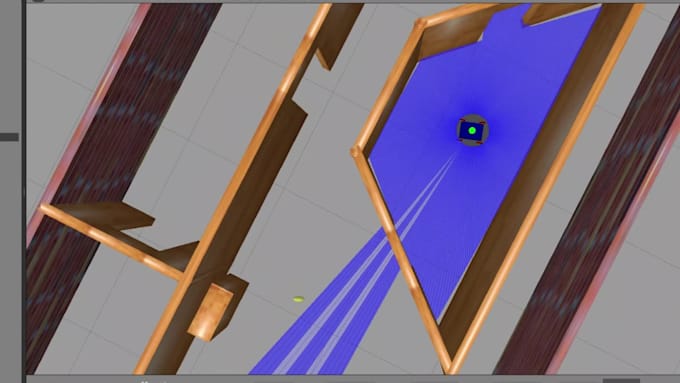
I built a four-wheel mecanum robot from scratch: designed the wheel and roller geometry, modeled it in URDF/Xacro, set up its Gazebo physics (including custom collision and friction tuning for non-standard wheels), configured its ros2_control hardware interface and controller, and fused wheel odometry with IMU data using robot_localization (EKF) to keep localization stable despite roller slip. On top of that, I configured Nav2's MPPI controller specifically for omnidirectional motion not the differential-drive defaults most tutorials and default configs assume.
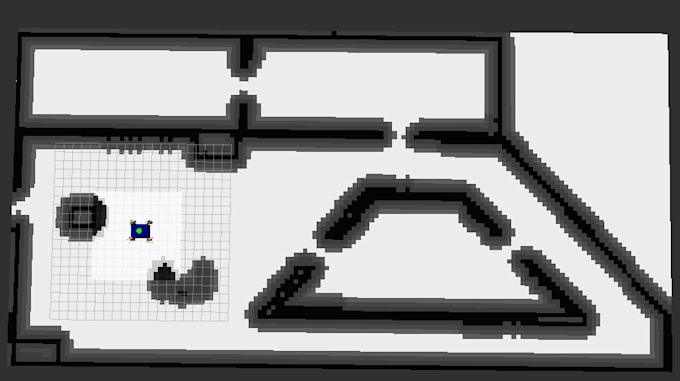
If you send me your files, I'll start by reviewing your URDF, Nav2 params, or controller YAML and give you a written diagnosis of what's actually wrong not just "this is broken," but the specific root cause and fix. From there, I can tune your MPPI or DWB controller to match your actual drive kinematics, fix your costmap and inflation layer settings, and set up or repair your EKF sensor fusion. Everything is tested in your simulation environment.