Browse categories
Explore
Fiverr Pro
English
$
USD
Expert Electrical Engineering Tutor, Circuit Theory, MATLAB and Electronics
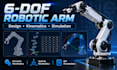
Are you looking for an Electrical Engineer to develop a robotic arm model, solve forward or inverse kinematics, or create a robotics simulation?
I provide customized robotics engineering solutions for researchers, engineers, developers, and automation projects.
MY SERVICES INCLUDE:
WHY CHOOSE MY SERVICE?
I have a master's-level background in Electrical Engineering and experience in engineering education and mathematical problem-solving.
I focus on accurate calculations, clear technical documentation, and solutions tailored to your robotic arm configuration.
Please contact me before ordering to discuss your robot configuration, software requirements, and project scope.
Control type:
Industrial Robots
Device brands:
Other
Programming language:
Python
•
JavaScript
Software:
Other
What robotics engineering services do you provide?
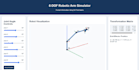
I provide robotic arm kinematics modeling, DH parameter calculations, forward and inverse kinematics, homogeneous transformation matrices, joint position calculations, and customized robotic arm simulation based on your project requirements.
Can you model a custom 6-DOF robotic arm?
Yes. I can develop a mathematical model for a custom 6-DOF robotic arm using its joint configuration, link dimensions, DH parameters, and transformation matrices. Please share your robot specifications before ordering.
Do you provide forward and inverse kinematics solutions?
Yes. I provide forward kinematics to calculate the end-effector pose from joint variables. Inverse kinematics can also be developed for an agreed robot configuration using an appropriate analytical or numerical method.
What information do you need to start my robotic arm project?
Please provide the number of joints, link dimensions, joint types, robot diagram or CAD model if available, required software, and expected deliverables. I will review the specifications and confirm the project scope.
Can you customize the robotic arm according to my requirements?
Yes. I can customize the kinematic model according to your robot geometry, joint limits, link dimensions, and required calculations. Custom simulation features can be discussed before placing an order.


