Browse categories
Explore
Fiverr Pro
English
$
USD
Passion Crafted Solutions Skillfully Delivered
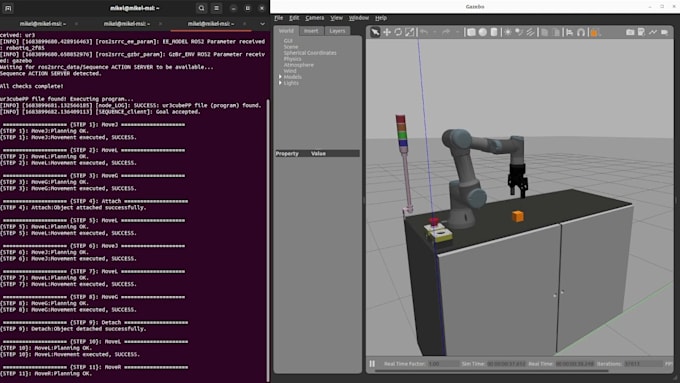
If you have a CAD Model of any Robotic Arm, Manipulator, Mobile Robot or Drone, I will convert into URDF (Unified Robot Description File), which is most commonly used file format for Multi body dynamic simulations, and perform simulation in any Physics Engine (Unity3D, Gazebo, PyBullet etc.). Using these techniques, you can test your system in simulation before deploying anything on real Robot.