Browse categories
Explore
Fiverr Pro
English
$
USD
pcb design, embedded system and firmware development
WELCOME!
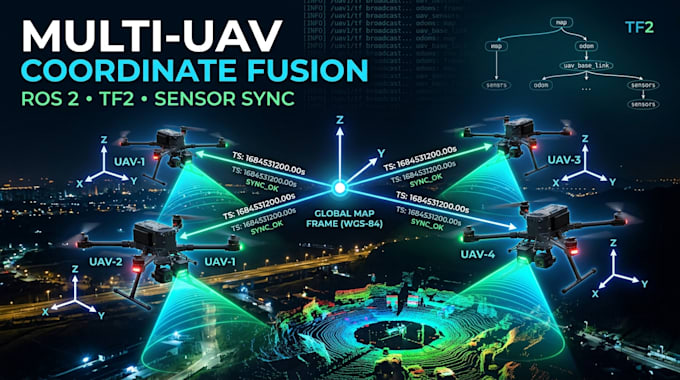
Need reliable sensor synchronization, TF2 transforms, or coordinate fusion for your ROS 2 robot or multi-UAV system? I can help you build, debug, and integrate robust ROS 2 solutions for drones, robots, autonomous systems, and sensor fusion applications.
What I can do:
Why choose my service?
You get clean, modular and well documented ROS 2 work focused on accuracy, reliability and easy integration. I can work with existing projects or develop the required solution from scratch.
Deliverables:
Working ROS 2 packages/nodes, TF2 configuration, synchronization/fusion implementation, launch files, documentation and testing guidance.
Message me before ordering so I can review your ROS 2 setup and recommend the right package.


Can you develop ROS 2 sensor synchronization?
Yes. I can synchronize LiDAR, cameras, IMU, GPS/GNSS and other ROS 2 sensor streams.
Can you fix ROS 2 TF2 errors?
Yes. I can diagnose TF2 trees, missing transforms, frame mismatches and transform timing issues.
Do you work with multi-UAV systems?
Yes. I can develop coordinate-frame and sensor-fusion solutions for multiple UAVs or drones.
Can you synchronize camera, LiDAR and IMU data?
Yes. I can design timestamp and message synchronization pipelines for ROS 2 sensor data.
Can you work with GPS or GNSS coordinate systems?
Yes. I can help integrate GPS/GNSS data with ROS 2 frames and coordinate transformations.
Can you develop ROS 2 sensor fusion nodes?
Yes. I can create modular ROS 2 nodes for sensor synchronization, transformation and fusion.
Can you fix coordinate frame problems in ROS 2?
Yes. I can troubleshoot frame IDs, TF2 relationships, timestamps and coordinate alignment.
Do you support drones and autonomous robots?
Yes. The service is suitable for UAVs, UGVs, robots and other autonomous platforms using ROS 2.
Can you integrate your solution into my existing ROS 2 project?
Yes. I can work with an existing ROS 2 workspace, packages, topics, nodes and launch files.
Can you develop the complete multi-UAV sensor fusion system?
Yes. Premium projects can combine synchronized sensors, TF2 and shared multi-UAV coordinates.