Browse categories
Explore
Fiverr Pro
English
$
USD
Virtual Assistant and Data Entry 3D Design and Programming
Are you working on a robotic manipulator design, academic assignment, or thesis and need accurate kinematic modeling?
I specialize in robotics and mathematical kinematics. I will develop, calculate, and validate the kinematic equations for your articulated robotic arm (from 2-DOF up to 6-DOF).
What I can do for you:
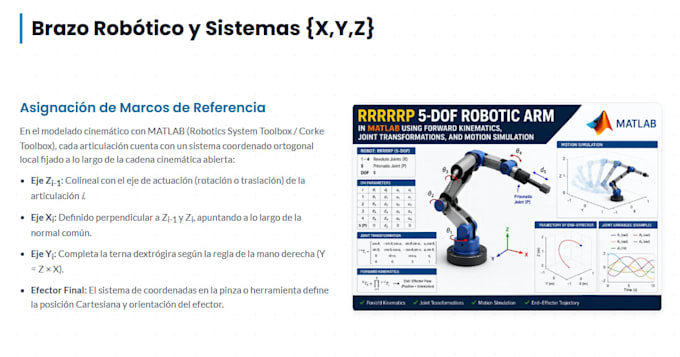
Frame Assignment:Correct coordinate frame placement based on standard or modified Denavit-Hartenberg conventions.
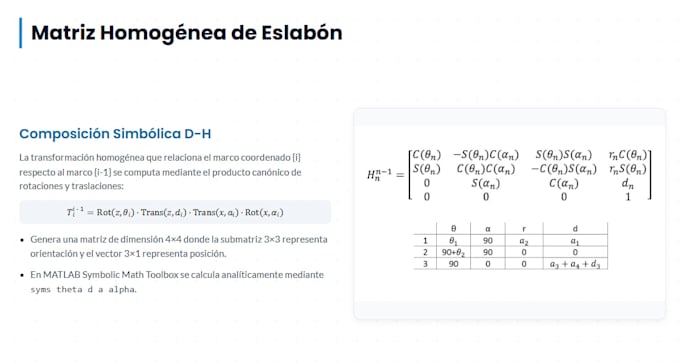
DH Parameters Table:** Accurate link lengths, twists, offsets, and joint angles.
Homogeneous Transformation Matrices (MTH): Step-by-step transformation matrices from base to end-effector (T0_n).
Forward Kinematics (MCD): Direct position and orientation calculation.
Inverse Kinematics (MCI): Geometric and analytical solutions, identifying reachable workspace and multiple joint configurations (elbow-up/elbow-down).
Differential Kinematics:Geometric/Analytical Jacobian, singular configuration analysis, and velocity mapping.
Code Implementation & Simulation: Custom MATLAB (Robotics Toolbox or native scripts) / Python code with 3D graphical visualization.
What you will receive:
1. Well-documented math
_k2jvqc.jpg)
Control type:
Industrial Robots
•
Collaborative Robots (Cobots)
Device brands:
KUKA
•
Yaskawa
Programming language:
MATLAB
Software:
Matlab
| (1) | ||
| (0) | ||
| (0) | ||
| (0) | ||
| (0) |
admiral_hik

Poland
Amazing work! Fast and great help!
$50
Price
1 day
Duration
| (1) | ||
| (0) | ||
| (0) | ||
| (0) | ||
| (0) |
admiral_hik
Poland
Amazing work! Fast and great help!
$50
Price
1 day
Duration