Browse categories
Explore
Fiverr Pro
English
$
USD
UAV Firmware Engineer for PX4 ArduPilot Betaflight ESC and Motion Control
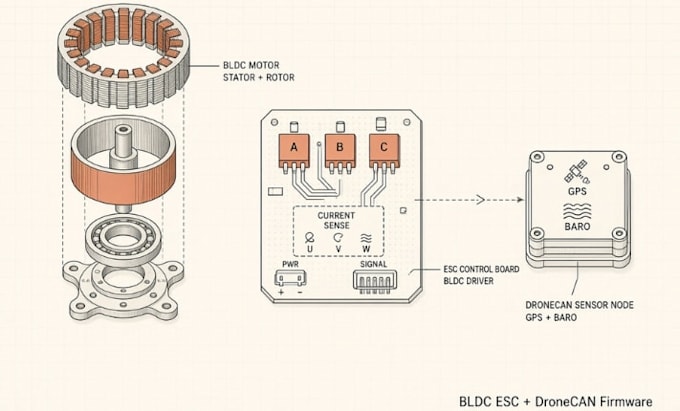
I develop production-focused BLDC ESC firmware for drones and robotics. This includes arming sequences, low-speed startup behavior, current feedback loops, over-current / over-voltage / thermal protection, stall detection, and bidirectional support where required. The firmware works with common STM32 targets and integrates cleanly with flight controllers using DShot-style digital protocols or classic PWM.
For the professional UAV segment I also build DroneCAN (UAVCAN) peripheral and sensor node firmware. Typical nodes include GPS, barometer, magnetometer, power modules, and smart sensors. You get standard message support, dynamic node allocation, parameter configuration, status reporting, and CAN bootloader-ready structure so the node behaves like a commercial AP_Periph-style device on both ArduPilot and PX4 systems.
What you receive:
Clean, modular embedded C firmware
Configurable PID and protection parameters
Current sensing and closed-loop control logic
DroneCAN / UAVCAN node implementation when ordered
Basic integration notes and test guidance
Source code ownership
Whether you need a robust drone ESC controller, a robotics BLDC driver, or a reliable CAN sensor node.....

Do you develop BLDC ESC motor control firmware with current sensing?
Yes. I implement current sensing, closed-loop PID speed/torque control, startup logic, and full protection handling (over-current, over-voltage, thermal, stall) for drone and robotics BLDC ESC applications.
Can you create DroneCAN or UAVCAN peripheral firmware?
Yes. I develop DroneCAN UAVCAN sensor nodes, GPS/barometer/power modules, and smart peripherals with standard messages, node status, parameters, and CAN bootloader support for ArduPilot and PX4.
What protection features are included in the ESC firmware?
Typical protection suite covers over-current, over-voltage, under-voltage, thermal limits, stall detection, and safe shutdown behavior so the motor and battery remain protected under load.
Do you support PID tuning and closed-loop control?
Yes. The firmware includes configurable PID loops for speed and current control, with guidance on tuning for your specific motor and application.
Will the firmware work with my existing flight controller or robotics controller?
Yes. I target common STM32 platforms and design the interface for PWM, digital protocols, or full DroneCAN integration so it connects cleanly to most modern controllers.
