Browse categories
English
$
USD
Connect to your AI
Robotics Engineer , ROS2 , Embedded Systems Specialist
Struggling with high-latency network drops or broken hardware-to-software interfaces? Let's bridge the gap.
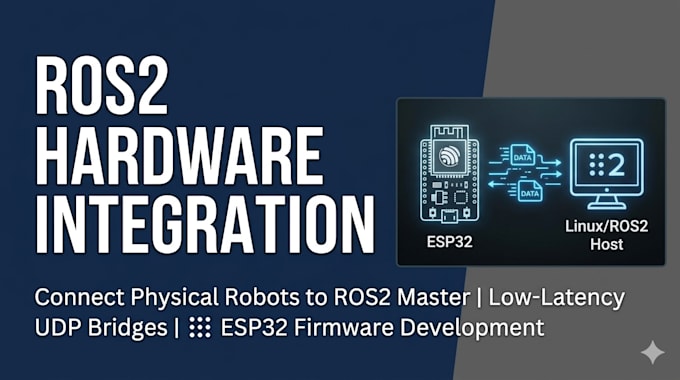
I am a robotics engineer specializing in low-latency physical systems integration. I design real-time communication bridges to connect your hardware directly with a master ROS2 host machine.
️ Core Technical Capabilities:
Why Partner With Me?
Please note: Real hardware setups require specific structural evaluation. Message me with your wiring details and compute configurations before placing an order.
Platform:
ESP32
Expertise:
Firmware development
•
Debugging
•
ROS
Do I need to ship my hardware to you?
• No. We will work entirely via remote network integration. I will provide the optimized ESP32 firmware and the master ROS2 workspace nodes [Explicit Claim]. You will run them locally, and we will debug any hardware timing or network communication states over screen-share or detailed text logs.
