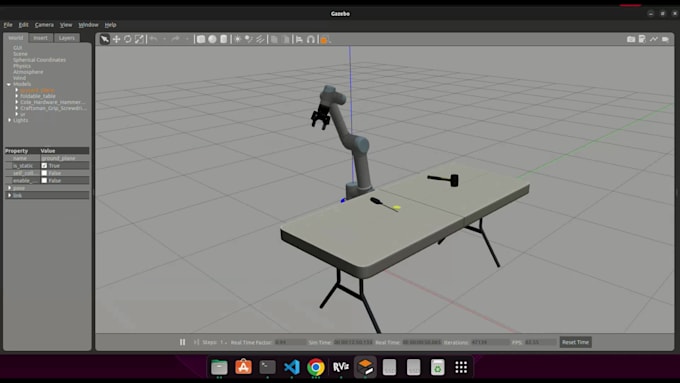
I will help to simulate robotic arms with motion planning and control in ROS2 Gazebo. I can deliver customized solutions tailored to your requirements.
- Robotic arm simulation in ROS 2 with MoveIt and Gazebo
- Path planning and motion control (using MoveIt planners)
- URDF/XACRO robot model setup
- Custom Gazebo environment configuration for testing
- Clean and modular ROS 2 workspace setup
- Video demo of the simulation running
- Support for custom manipulator models
Why Choose Me?
- Robotics engineering background
- Experience with ROS2 simulations
- Clean & scalable ROS 2 packages