Browse categories
Explore
Fiverr Pro
English
$
USD
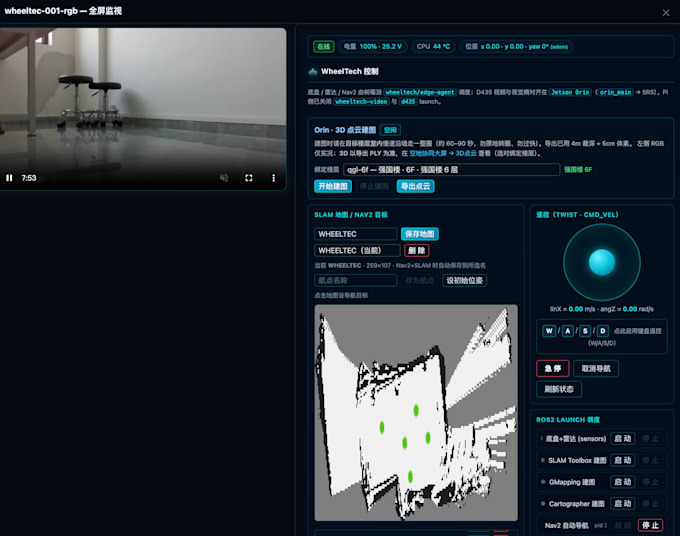
Got a Wheeltec mobile robot but stuck on ROS2 setup, SLAM, or autonomous navigation? I can help.
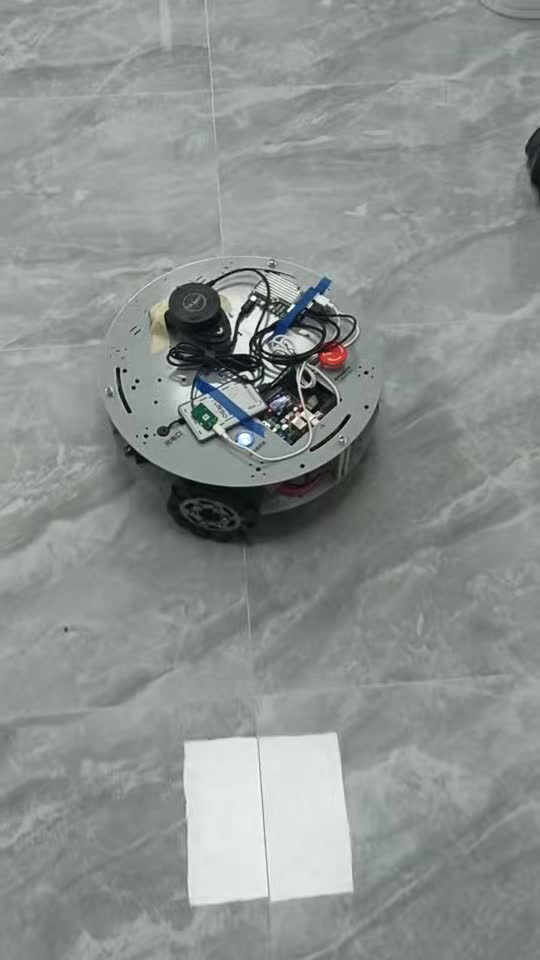
I specialize in Wheeltec platforms running ROS2 Humble and the official wheeltec_ros2 stack on Raspberry Pi and Jetson.
What I do:
Supported: Wheeltec Mecanum, Omni, and Ackermann kits with official wheeltec_ros2.
You provide: robot model, SSH/VNC access, and your goal.
You get: working launch files, saved map (Standard+), and a short runbook.
Message me your Wheeltec model before ordering I'll confirm scope and timeline.